10.18. Compute Biased Features (Bounding Box)
Group (Subgroup)
Generic (Spatial)
Description
This Filter flags each Feature as biased or unbiased by the outer surfaces of the sample, producing a feature-level boolean array suitable for excluding biased features from downstream statistical analyses (size distributions, shape distributions, ODFs, etc.).
Why Bias Matters for Statistics
When a sample volume is cut out of a larger material, some grains are truncated by the cut. If only size or shape statistics are needed, surface-touching features like those flagged by Compute Surface Features can be excluded – but that undercounts the problem. Larger grains are more likely to touch any given surface simply because they are larger, so excluding only surface-touching features still leaves a size-dependent sampling bias: small grains that don’t touch the surface are over-represented relative to large grains that do. The biased-feature flag produced here corrects for this by identifying which features’ centroids are close enough to a boundary that they are statistically suspect, regardless of whether the feature itself touches the boundary.
How This Filter Works
The algorithm for determining whether a Feature is biased is as follows:
The centroids of all Features are calculated
All Features are tested to determine if they touch an outer surface of the sample
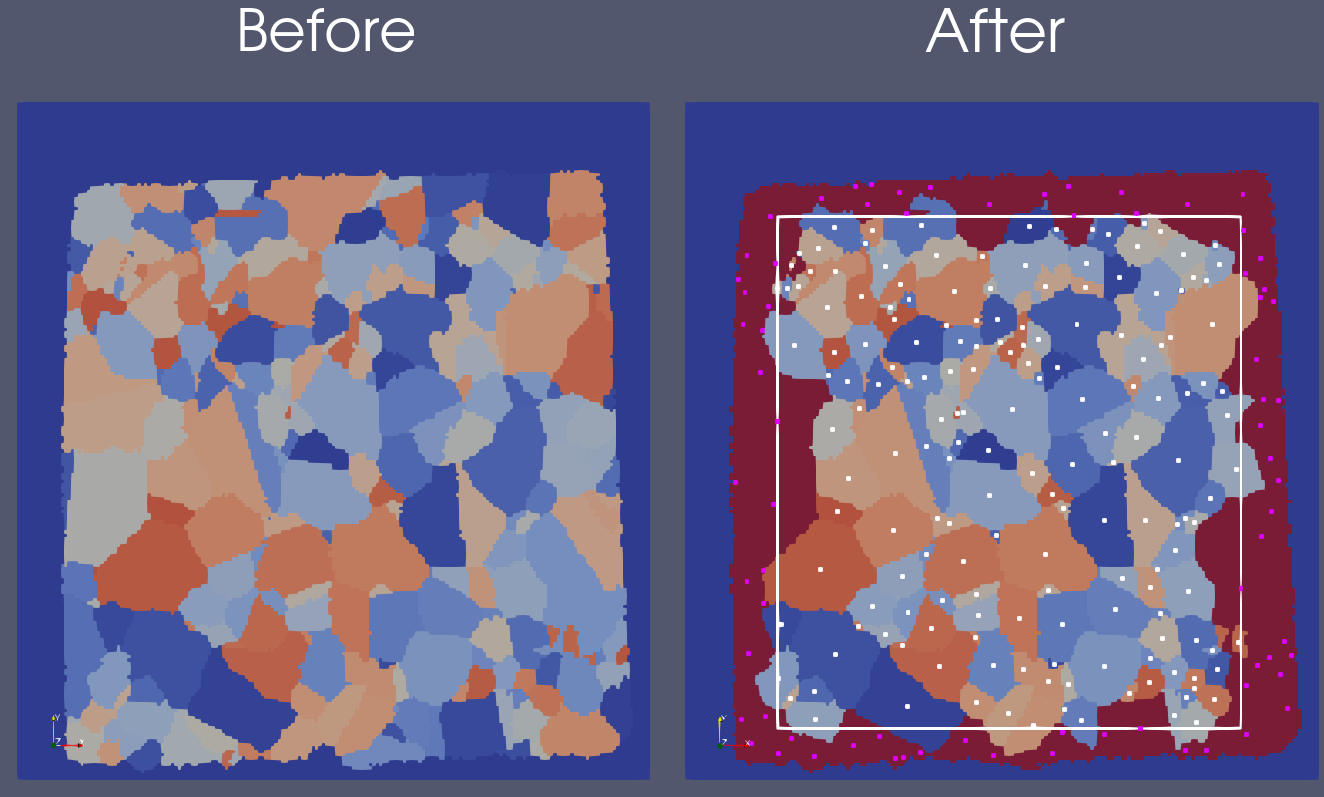
The largest box is found that does not include any of the centroids of Features that intersect an outer surface of the sample
Each Feature’s centroid is checked to see whether it lies within the box.
If a Feature’s centroid lies within the box, then the Feature is said to be unbiased, and if it lies outside the box, then the Feature is said to be biased.
By definition of the box, no Feature that intersects an outer surface of the sample can be considered unbiased, but it should be noted that Features that do not intersect the outer surfaces may still be considered biased. This algorithm works to determine the biased Features because all Features have one (and only one) centroid, no matter their size. Generally, this method will deem more small Features biased than the set of Features that just intersect the outer surfaces - and this corrects for the increased likelihood that larger Features will touch an outer surface.
Note: This Filter is a modification of an algorithm from Dave Rowenhorst (Naval Research Laboratory).
The images below show the feature ids before and after running this filter. The image on the right shows the biased features colored in red, the unbiased features colored by their feature id, the bounding box (described in step 3 of the algorithm above), and the feature centroids (white for unbiased and purple for biased).
Required Input Sources
Feature Centroids – produced by Compute Feature Centroids.
Surface Features – produced by Compute Surface Features or as an optional output of Compute Feature Neighbors.
Feature Phases (only when applying to a single phase) – produced by Compute Feature Phases.
Input Parameter(s)
Parameter Name |
Parameter Type |
Parameter Notes |
Description |
|---|---|---|---|
Apply Phase by Phase |
Bool |
Whether to apply the biased Features algorithm per Ensemble |
|
Image Geometry |
Geometry Selection |
Image |
The selected geometry in which to the (biased) features belong |
Input Feature Data
Parameter Name |
Parameter Type |
Parameter Notes |
Description |
|---|---|---|---|
Centroids |
Array Selection |
Allowed Types: float32 Comp. Shape: 3 |
X, Y, Z coordinates of Feature center of mass |
Surface Features |
Array Selection |
Allowed Types: uint8, boolean Comp. Shape: 1 |
Flag of 1 if Feature touches an outer surface or of 0 if it does not |
Phases |
Array Selection |
Allowed Types: int32 Comp. Shape: 1 |
Specifies to which Ensemble each Feature belongs. Only required if Apply Phase by Phase is checked |
Output Feature Data
Parameter Name |
Parameter Type |
Parameter Notes |
Description |
|---|---|---|---|
Biased Features |
DataObjectName |
Flag of 1 if Feature is biased or of 0 if it is not |
Example Pipelines
ComputeBiasedFeatures.d3dpipeline
License & Copyright
Please see the description file distributed with this Plugin
DREAM3D-NX Help
If you need help, need to file a bug report or want to request a new feature, please head over to the DREAM3DNX-Issues GitHub site where the community of DREAM3D-NX users can help answer your questions.