10.130. Replace Element Attributes with Neighbor (Threshold)
Group (Subgroup)
Processing (Cleanup)
Description
This Filter replaces the attributes of cells that fail a user-defined threshold with the attributes of one of their neighbors – specifically, the neighbor with the maximum or minimum value of the same scalar. It is a generic threshold-and-replace cleanup tool: any cell-level scalar can drive the threshold, and all cell-level arrays in the same attribute matrix follow the chosen neighbor’s values.
This filter is most often used to clean up EBSD data using a confidence-related scalar (Confidence Index, Image Quality, MAD, etc.), but it works on any cell-level scalar.
How This Filter Works
For every cell, compare its value of the Selected Array to the Threshold Value using the Comparison Operator (less-than or greater-than).
For each cell that passes the comparison (i.e., is flagged for replacement), examine its 6 face-neighbors.
Among the neighbors that do not pass the comparison, find the one with the maximum (when operator is
<) or minimum (when operator is>) value of the same scalar. This is the “best” neighbor.Copy all cell-level arrays in the same attribute matrix from that best neighbor into the flagged cell.
If a flagged cell has only flagged neighbors (i.e., none of its neighbors pass the threshold), it is left unchanged in this pass.
Comparison Operator
< [Less Than] [0]: Targets cells whose scalar is less than the threshold. Replacement neighbor is the one with the highest scalar value among neighbors that exceed the threshold. Use this for measures where higher = better (Confidence Index, Image Quality).
> [Greater Than] [1]: Targets cells whose scalar is greater than the threshold. Replacement neighbor is the one with the lowest scalar value among neighbors that fall below the threshold. Use this for measures where lower = better (Mean Angular Deviation, scan error metrics).
Loop Until Gone
By default, the filter runs a single pass. If a flagged cell’s neighbors are all flagged in that pass, the cell is left alone. Enabling Loop Until Gone repeats the algorithm until every flagged cell has been replaced (typically because flag-replacements propagate inward across multiple passes).
Caution: Flood Fill Behavior
If the threshold is set too aggressively or the dataset has large contiguous regions of low-quality cells, Loop Until Gone can act like a flood-fill, propagating one neighbor’s data across an entire region. The end result may bear little resemblance to the true microstructure. Always inspect the output and, if grain morphology has shifted dramatically, lower the Threshold Value or run a single pass.
Original Data |
Threshold CI < 0.1 |
After Running Filter |
True Data |
|---|---|---|---|
|
|
|
|
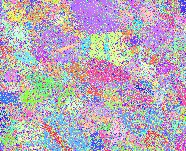
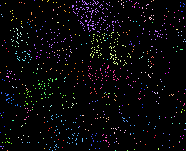
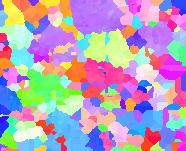
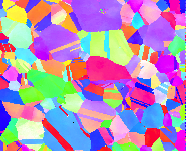
The example above shows what happens when too much of the data is below threshold: most fine grains and twins do not match the true microstructure.
Example Use Cases
Reasonable Use of the Filter
Original Data |
After Running Filter |
True Data |
|
|---|---|---|---|
|
|
|
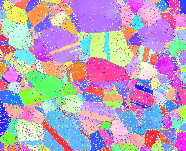
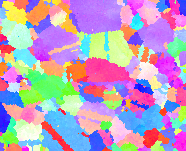
TSL Data (.ang) – Using Confidence Index
EDAX/TSL ANG files include a Confidence Index (CI) array that ranges from 0.0 (no confidence) to 1.0 (absolute confidence). To clean up cells with poor indexing, use:
Filter Parameter |
Value |
|---|---|
Threshold Value |
0.1 |
Operator |
< |
Selected Array |
[DataContainer] / CellData / Confidence Index |
Loop Until Gone |
User dependent |
This says: for every cell with CI < 0.1, find the neighbor with the highest CI among those above 0.1, and copy that neighbor’s data into the cell.
Oxford/Bruker (.ctf) – Using Error
CTF files do not include a Confidence Index, but they do have an Error value that defaults to 0 for indexed points and is non-zero for non-indexed points. This is the inverse direction from CI:
Filter Parameter |
Value |
|---|---|
Threshold Value |
0.0 |
Operator |
> |
Selected Array |
[DataContainer] / CellData / Error |
Loop Until Gone |
User dependent |
Original Data |
After Running Filter |
|---|---|
|
|
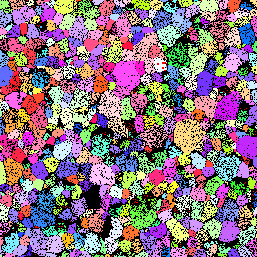
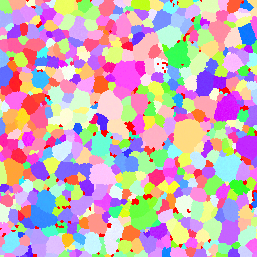
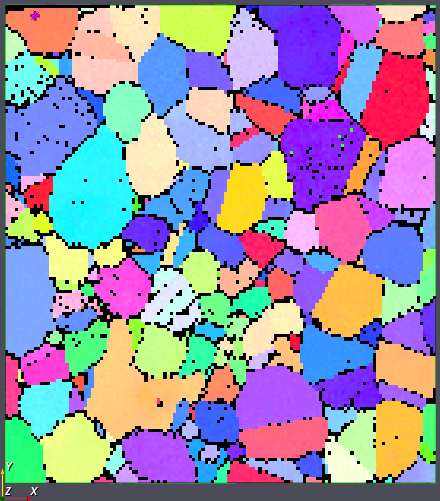
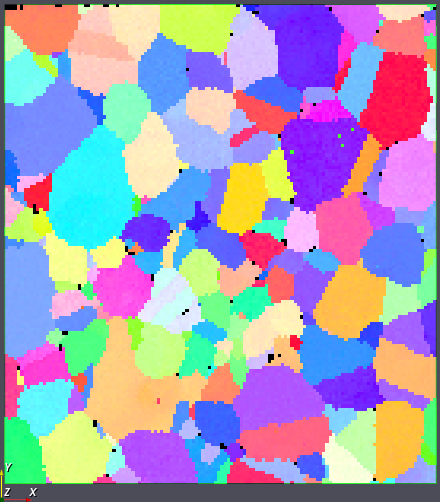
The black pixels in the original are unindexed cells (Error > 0) and are filled in by the filter.
Required Input Sources
Selected Scalar Array – any single-component cell-level scalar suitable for thresholding. Common sources: confidence/quality arrays from Read H5EBSD, Read CTF Data, or Read ANG Data, or any computed per-cell scalar.
Input Parameter(s)
Parameter Name |
Parameter Type |
Parameter Notes |
Description |
|---|---|---|---|
Threshold Value |
Scalar Value |
Float32 |
The value to of the threshold |
Comparison Operator |
Choices |
The operator to use for comparisons. 0=Less, 1=Greater Than |
|
Loop Until Gone |
Bool |
The algorithm will keep looping until all pixels have been evaluated |
Input Cell Data
Parameter Name |
Parameter Type |
Parameter Notes |
Description |
|---|---|---|---|
Selected Image Geometry |
Geometry Selection |
Image |
The target geometry |
Input Comparison Array |
Array Selection |
Allowed Types: int8, uint8, int16, uint16, int32, uint32, int64, uint64, float32, float64, boolean Comp. Shape: 1 |
The DataPath to the input array to use for comparison |
Example Pipelines
The example pipeline (pipelines/Examples/ReplaceElementAttributesWithNeighbor.d3dpipeline) will give output similar to the following images.
Before Filter |
After Filter |
|---|---|
|
|
License & Copyright
Please see the description file distributed with this Plugin
DREAM3D-NX Help
If you need help, need to file a bug report or want to request a new feature, please head over to the DREAM3DNX-Issues GitHub site where the community of DREAM3D-NX users can help answer your questions.